Robotics & Embodied AI
RoboLLM
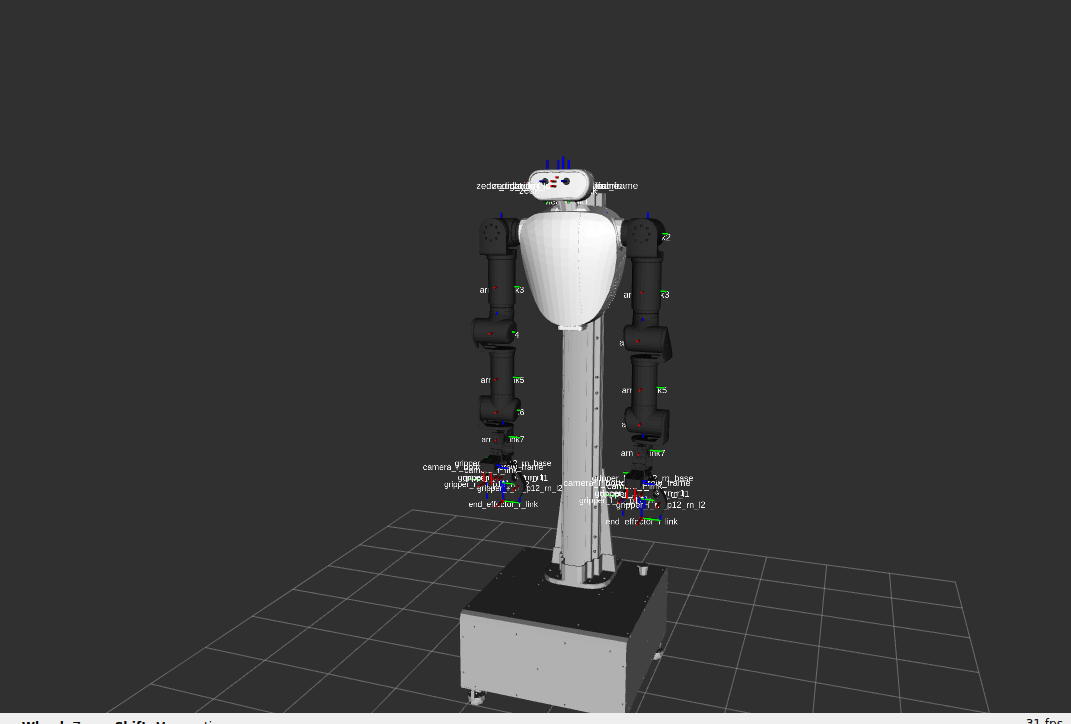
Robot workbench — webcam hand-teleoperation, humanoid motion mirroring, and LLM-driven robot control experiments on ROS 2.
Explore projectAutonomous drone flight controller running on a Raspberry Pi Pico W. Written in Rust with PID and LQG control loops for stable attitude and position hold.
Follow the project links for its source, documentation and available demo.
Robot workbench — webcam hand-teleoperation, humanoid motion mirroring, and LLM-driven robot control experiments on ROS 2.
Explore projectAI-powered manufacturing platform for custom jewelry — sketch-to-CAD conversion with downstream CNC planning and job orchestration.
Explore project