Robotics & Embodied AI
RoboLLM
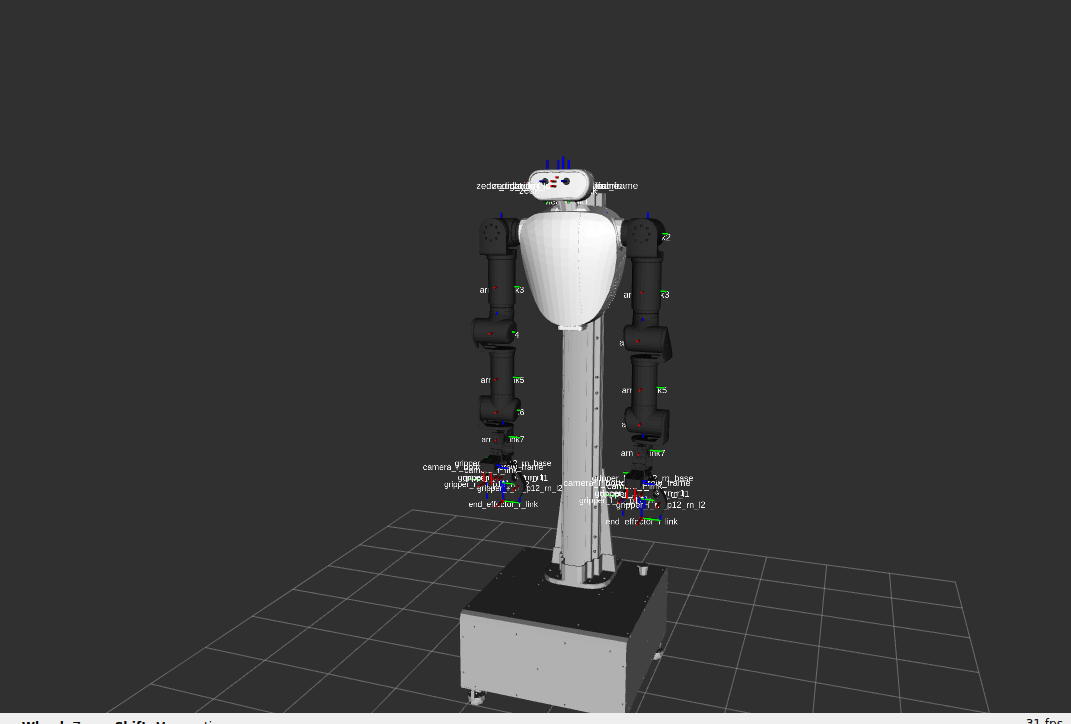
Robot workbench — webcam hand-teleoperation, humanoid motion mirroring, and LLM-driven robot control experiments on ROS 2.
Explore projectHarness & meta-harness engineering, AI agents and robotics — shipped end-to-end.
I'm Santapong Sondhi, a software, AI and robotics engineer. I build tools, explore how intelligent systems interact with the world, and write about what I learn along the way.
A little more about meRobot workbench — webcam hand-teleoperation, humanoid motion mirroring, and LLM-driven robot control experiments on ROS 2.
Explore projectObservable, deterministic meta-harness for local AI coding agents — supervises Codex and Claude Code through one control plane with static strategy selection, verifier-gated bounded loops, isolated Git worktrees, a durable event trace and the ACR-ARCH selector benchmark.
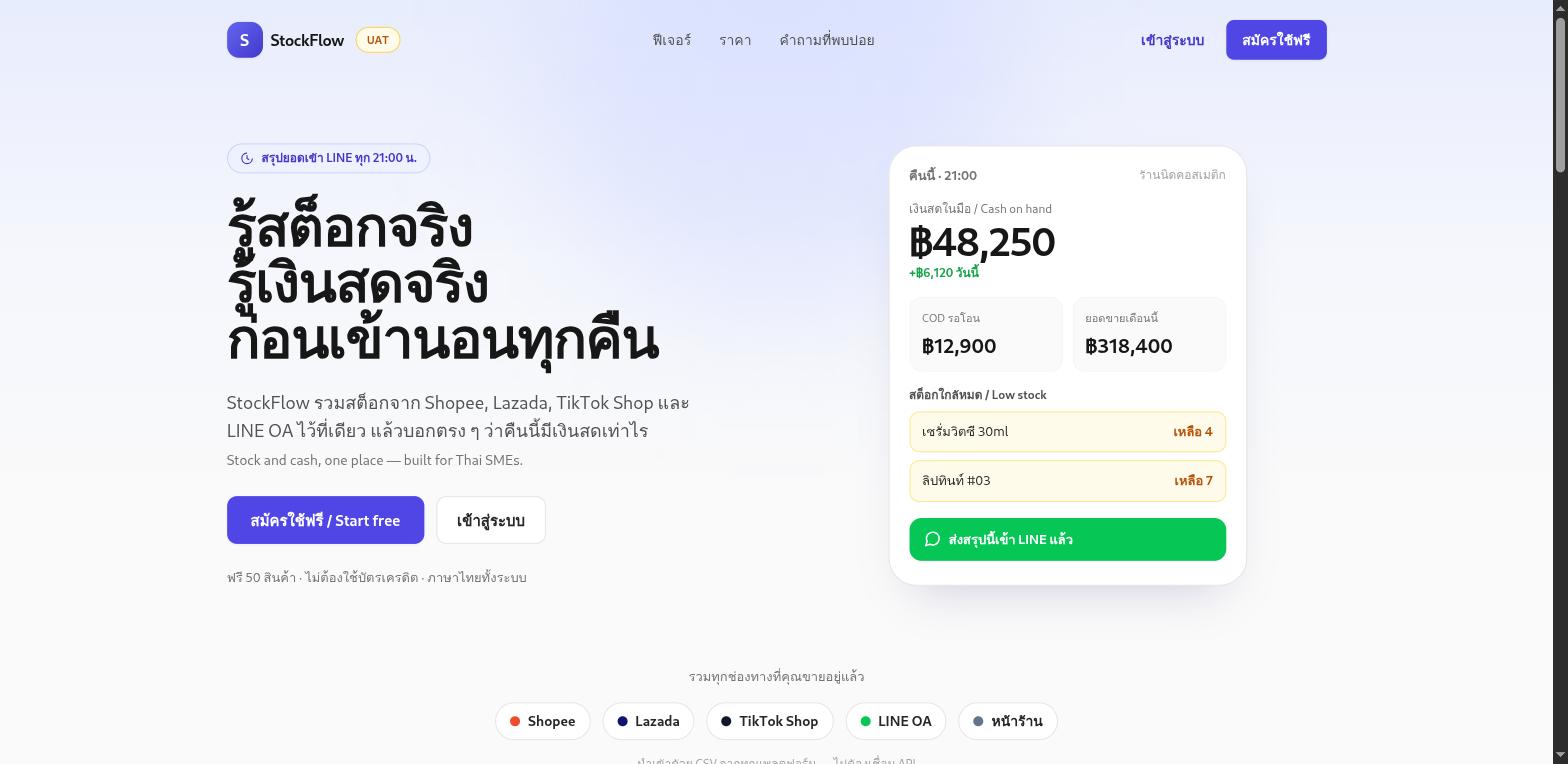
Explore projectSmart-Inventory — stock and cash-flow SaaS for Thai SMEs. Pools inventory from Shopee, Lazada, TikTok Shop and LINE OA into one place and tells you tonight's cash position, with a nightly LINE summary.
Explore project
How this site went from misattributed to ranked #1 for my name and legible to AI answer engines in an afternoon: canonical domain, per-page metadata, JSON-LD, a dynamic sitemap, Search Console as a diagnostic — then the GEO layer: AI-crawler allowances, llms.txt, RSS, and content concrete enough to quote.
Embodied AI is the field: intelligence closing a perception–action loop against physics. Cross-embodiment (X-embodiment) is a scaling bet inside it — and the RT-X numbers say it pays off asymmetrically: 27.3%→75.8% at 55B params, but worse-than-solo at 35M. Diversity beats volume, human video is the cheapest body, and the evaluation harness matters at every scale.
RoboLLM's four principles in practice: one ROS 2 bridge for MCP and dashboard, a physical-arm chain where no model ever touches PWM, gesture pick-and-place and fist-triggered wall welding with collision-verified standoffs — and why it is the same shape as a meta-harness.
How perception, learning and action come together in embodied systems.
Explore the work
How to make agent workflows observable, bounded and easier to trust.
Explore the work
How engineering becomes useful software for everyday work.
Explore the work