RoboLLM's four principles in practice: one ROS 2 bridge for MCP and dashboard, a physical-arm chain where no model ever touches PWM, gesture pick-and-place and fist-triggered wall welding with collision-verified standoffs — and why it is the same shape as a meta-harness.
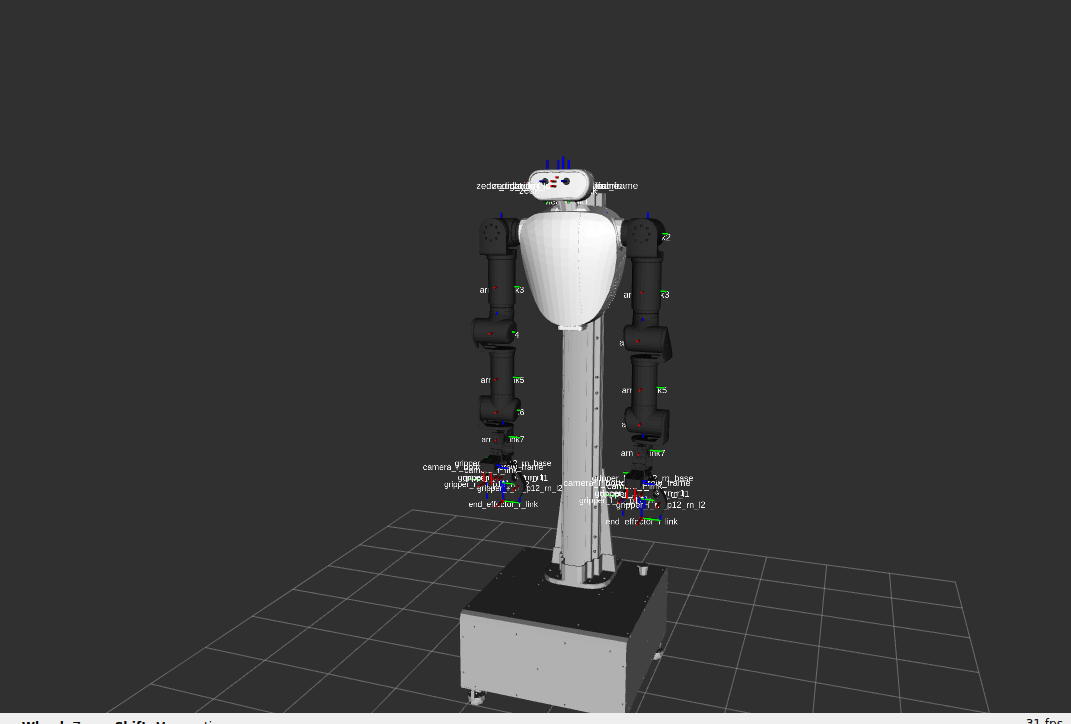
Building the RoboLLM humanoid mirror: MoveIt ships no humanoid, your hips are invisible at a desk, cv2.flip swaps MediaPipe left/right labels (measured 20–38×), and never compute a speed limit from subscriber arrival times. Verified 0.0000° against /compute_fk.
Full-body Talos mirror in RoboLLM: pink QP differential IK lost to direct joint copy in an A/B — wrist error 0→5.31 mm, 31–58 ms ticks vs a 20 ms budget, a crash on partial visibility, and an orientation 'win' with no ground truth. Why Pose-only input caps fidelity and when QP actually pays.
Autonomous drone flight controller running on a Raspberry Pi Pico W. Written in Rust with PID and LQG control loops for stable attitude and position hold.